CurrentSky · AISHIP
Flight Computer
Every correction at the perfect moment.
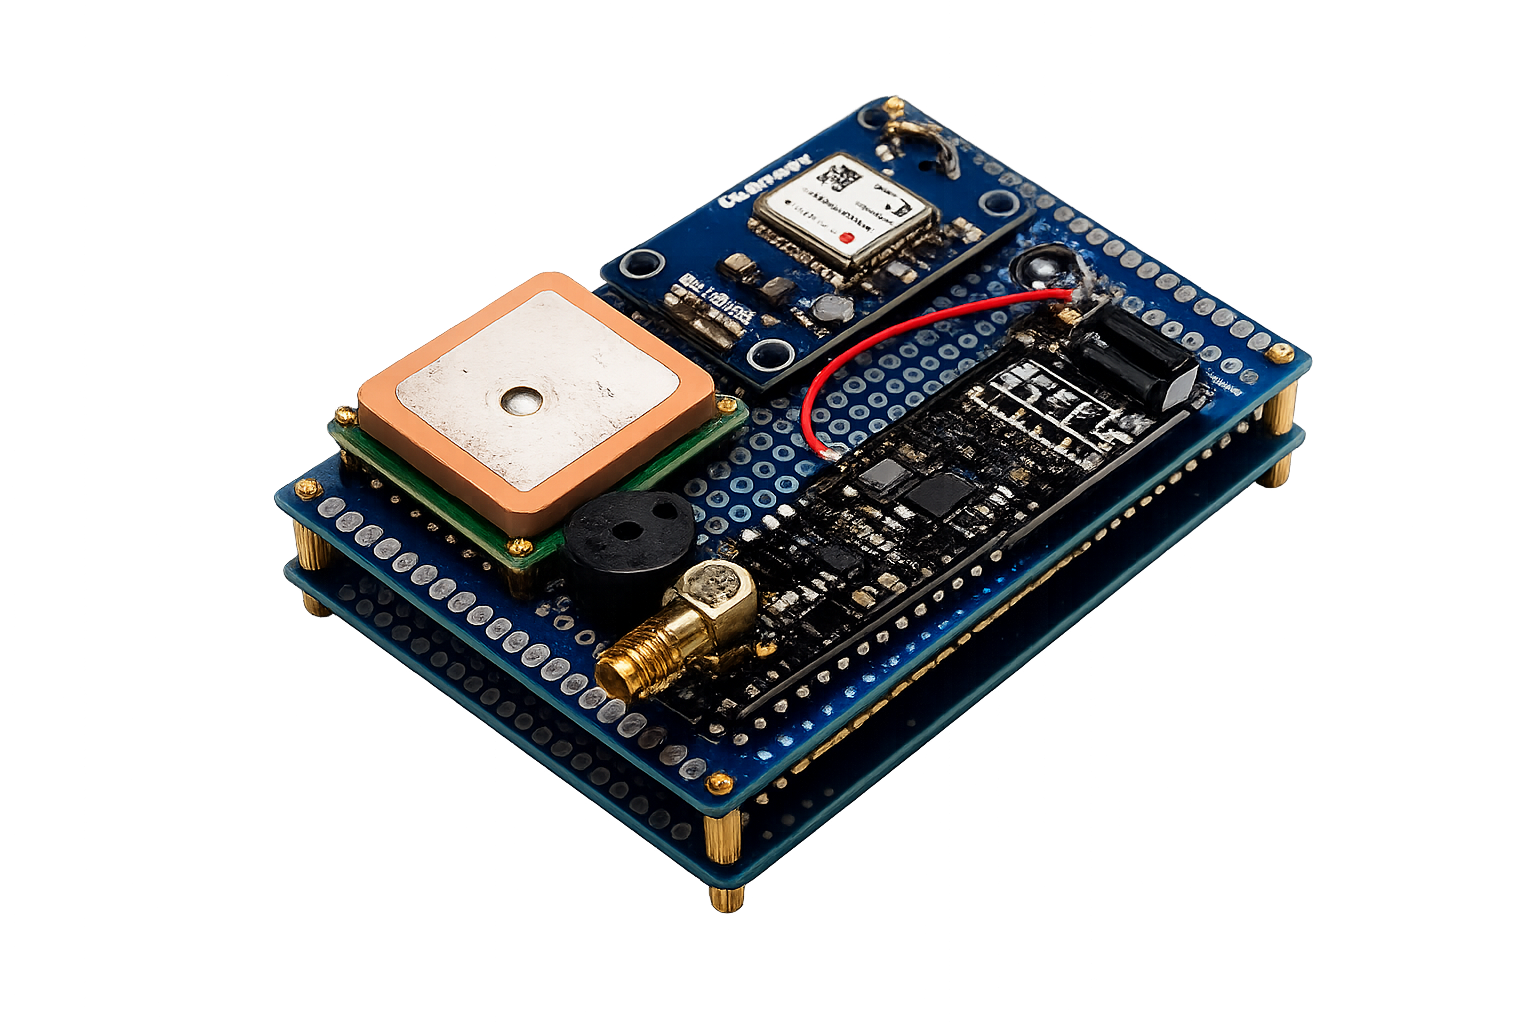
KAIROS is the custom flight computer built to keep AISHIP balanced on its own thrust — sensing, deciding, and acting about a hundred times a second.
What is KAIROS
A computer built for balance
Where a normal drone spreads its motors wide for stability, a thrust-vectored drone balances on its own thrust like a pencil on a fingertip — it must actively correct its attitude many times a second to stay upright. KAIROS is the on-board intelligence that turns raw sensor data into precise control commands in real time, continuously and autonomously.
The name
The Greeks had two words for time. Chronos is measured time — the ticking of a clock. Kairos (καιρός) is the opportune moment, when everything lines up and action matters most. A flight controller lives entirely in kairos: about a hundred perfectly-timed decisions every second.
CurrentSky → AISHIP → KAIROS
How it works
Sense. Decide. Act.
01
Sense
A 9-axis motion sensor fuses gyroscope, accelerometer, and magnetometer into a single drift-corrected picture of how the vehicle is oriented in 3D space.
02
Decide
A real-time controller compares actual attitude against the target and computes the exact correction — fast enough to cancel a tip-over before it becomes a fall.
03
Act
KAIROS steers the direction of thrust to hold balance and course — then loops back to sense, about a hundred times every second.
Capabilities
What it does
Active stabilization
Continuous high-rate attitude correction keeps a thrust-vectored vehicle upright.
Adaptive radio
Scans the 2.4 GHz band, switches channel on the fly and remembers the last good one.
Live telemetry
Streams flight data to the ground in real time over a wireless link.
Safety monitoring
Start, stop and emergency abort. If the link to the ground is lost, the motors stop.
Battery protection
Monitors pack voltage and cuts the motors when the battery runs low.
Navigation · in development
GPS, barometer, optical flow and a laser rangefinder already stream data. Position hold and point-to-point flight are being built.
Locator beacon
An audible “find me” signal to locate the vehicle.
Companion app
A desktop app for tuning, live monitoring and bench tests.
In the lab
Built, not rendered
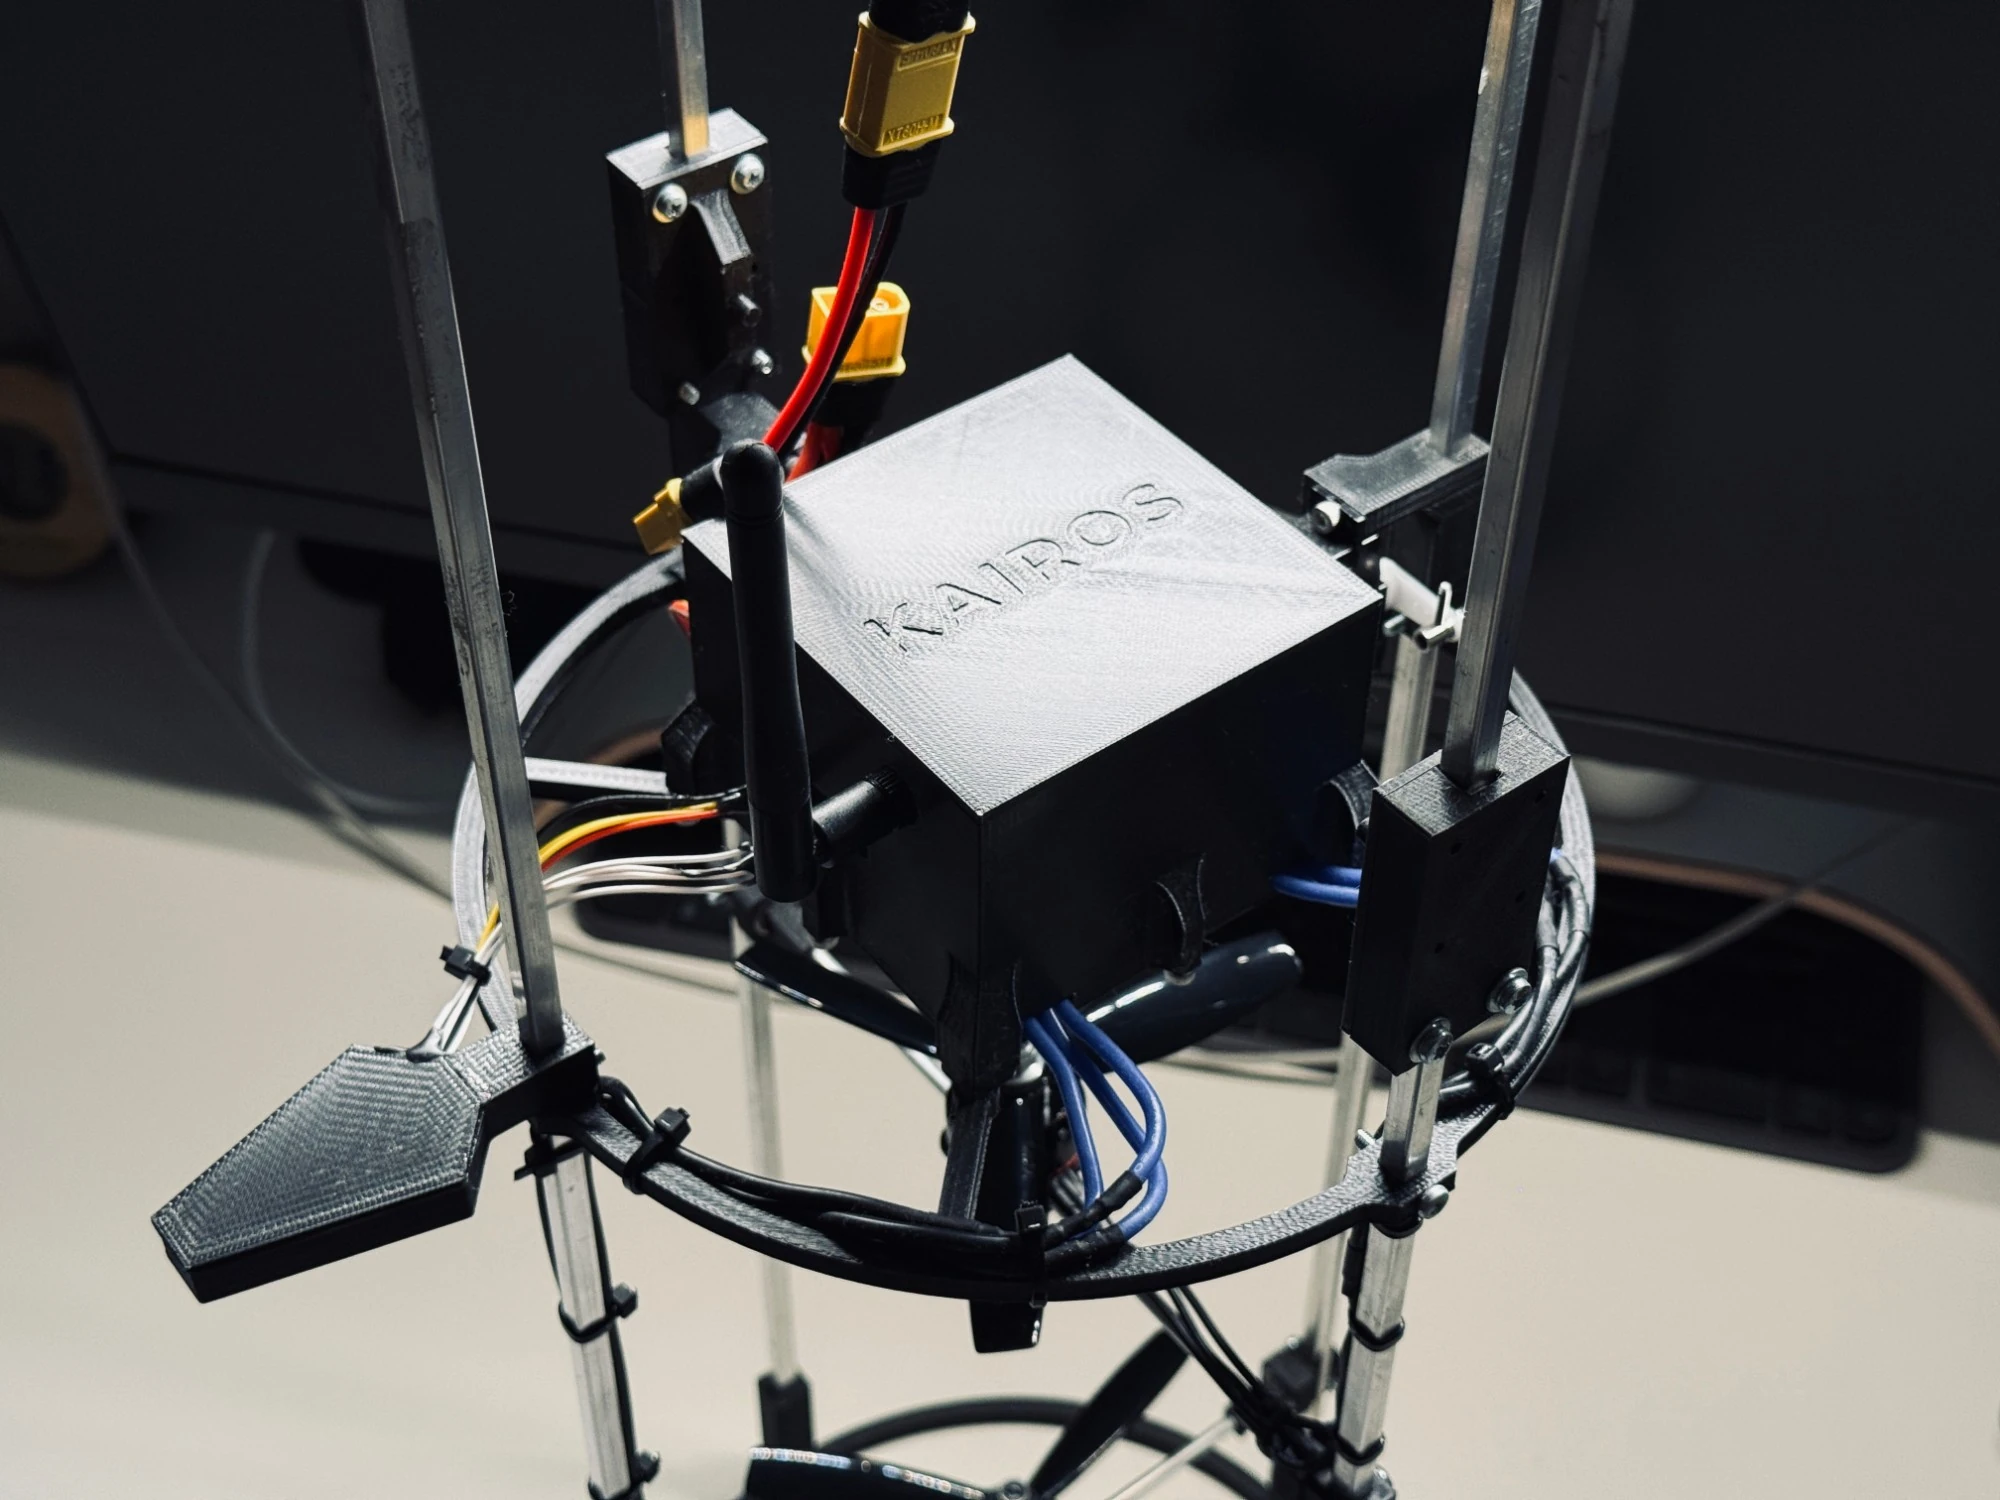
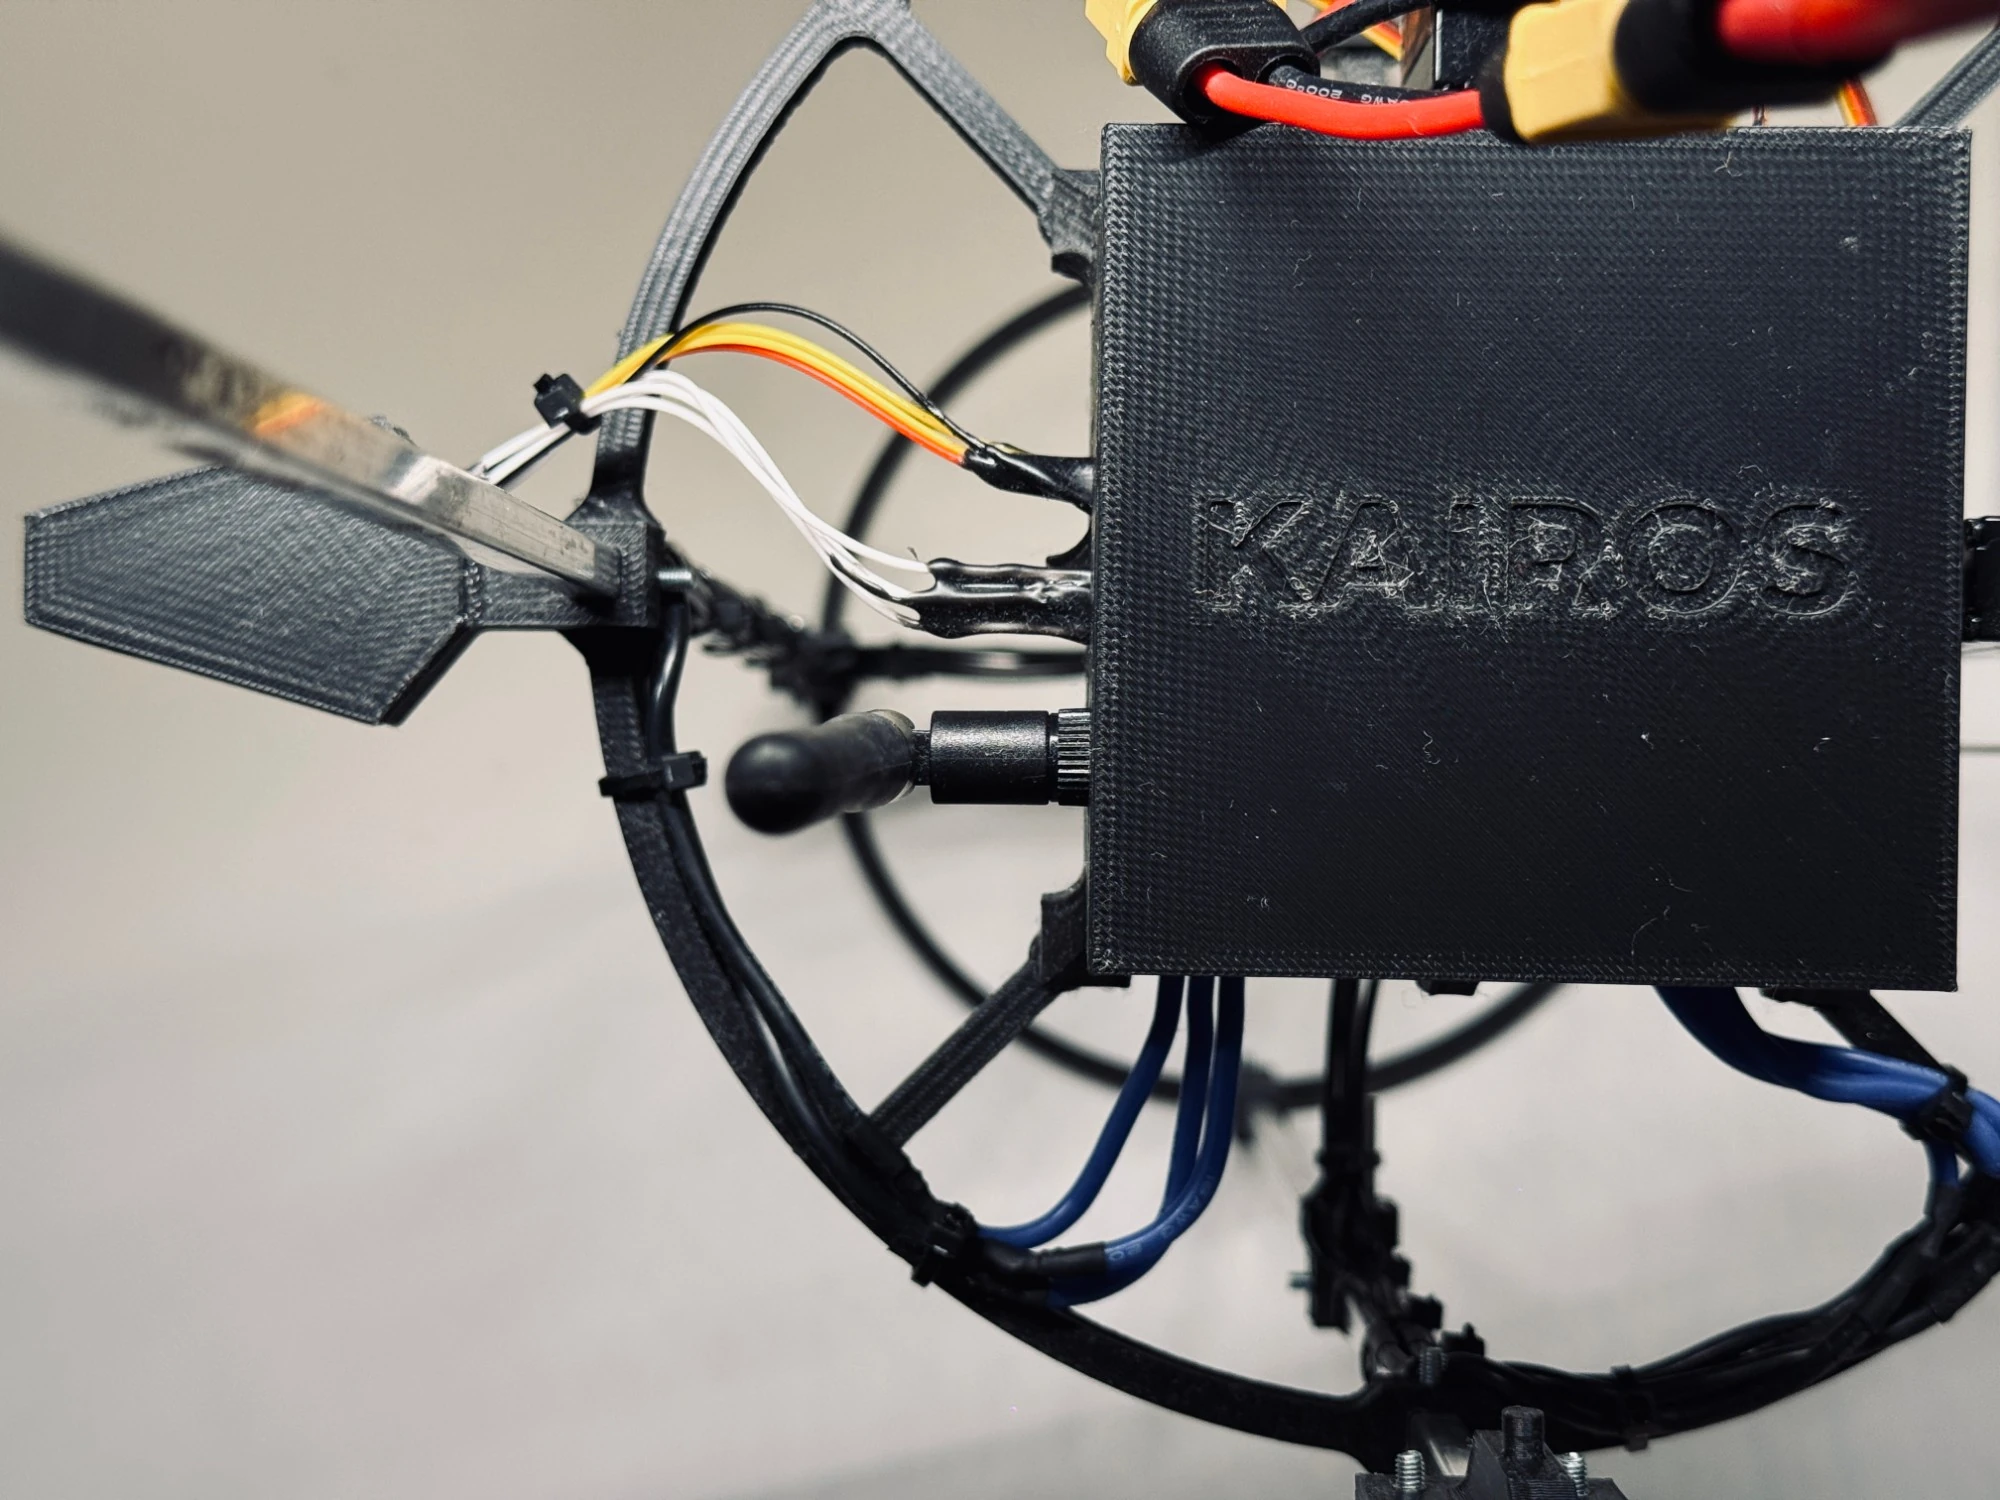
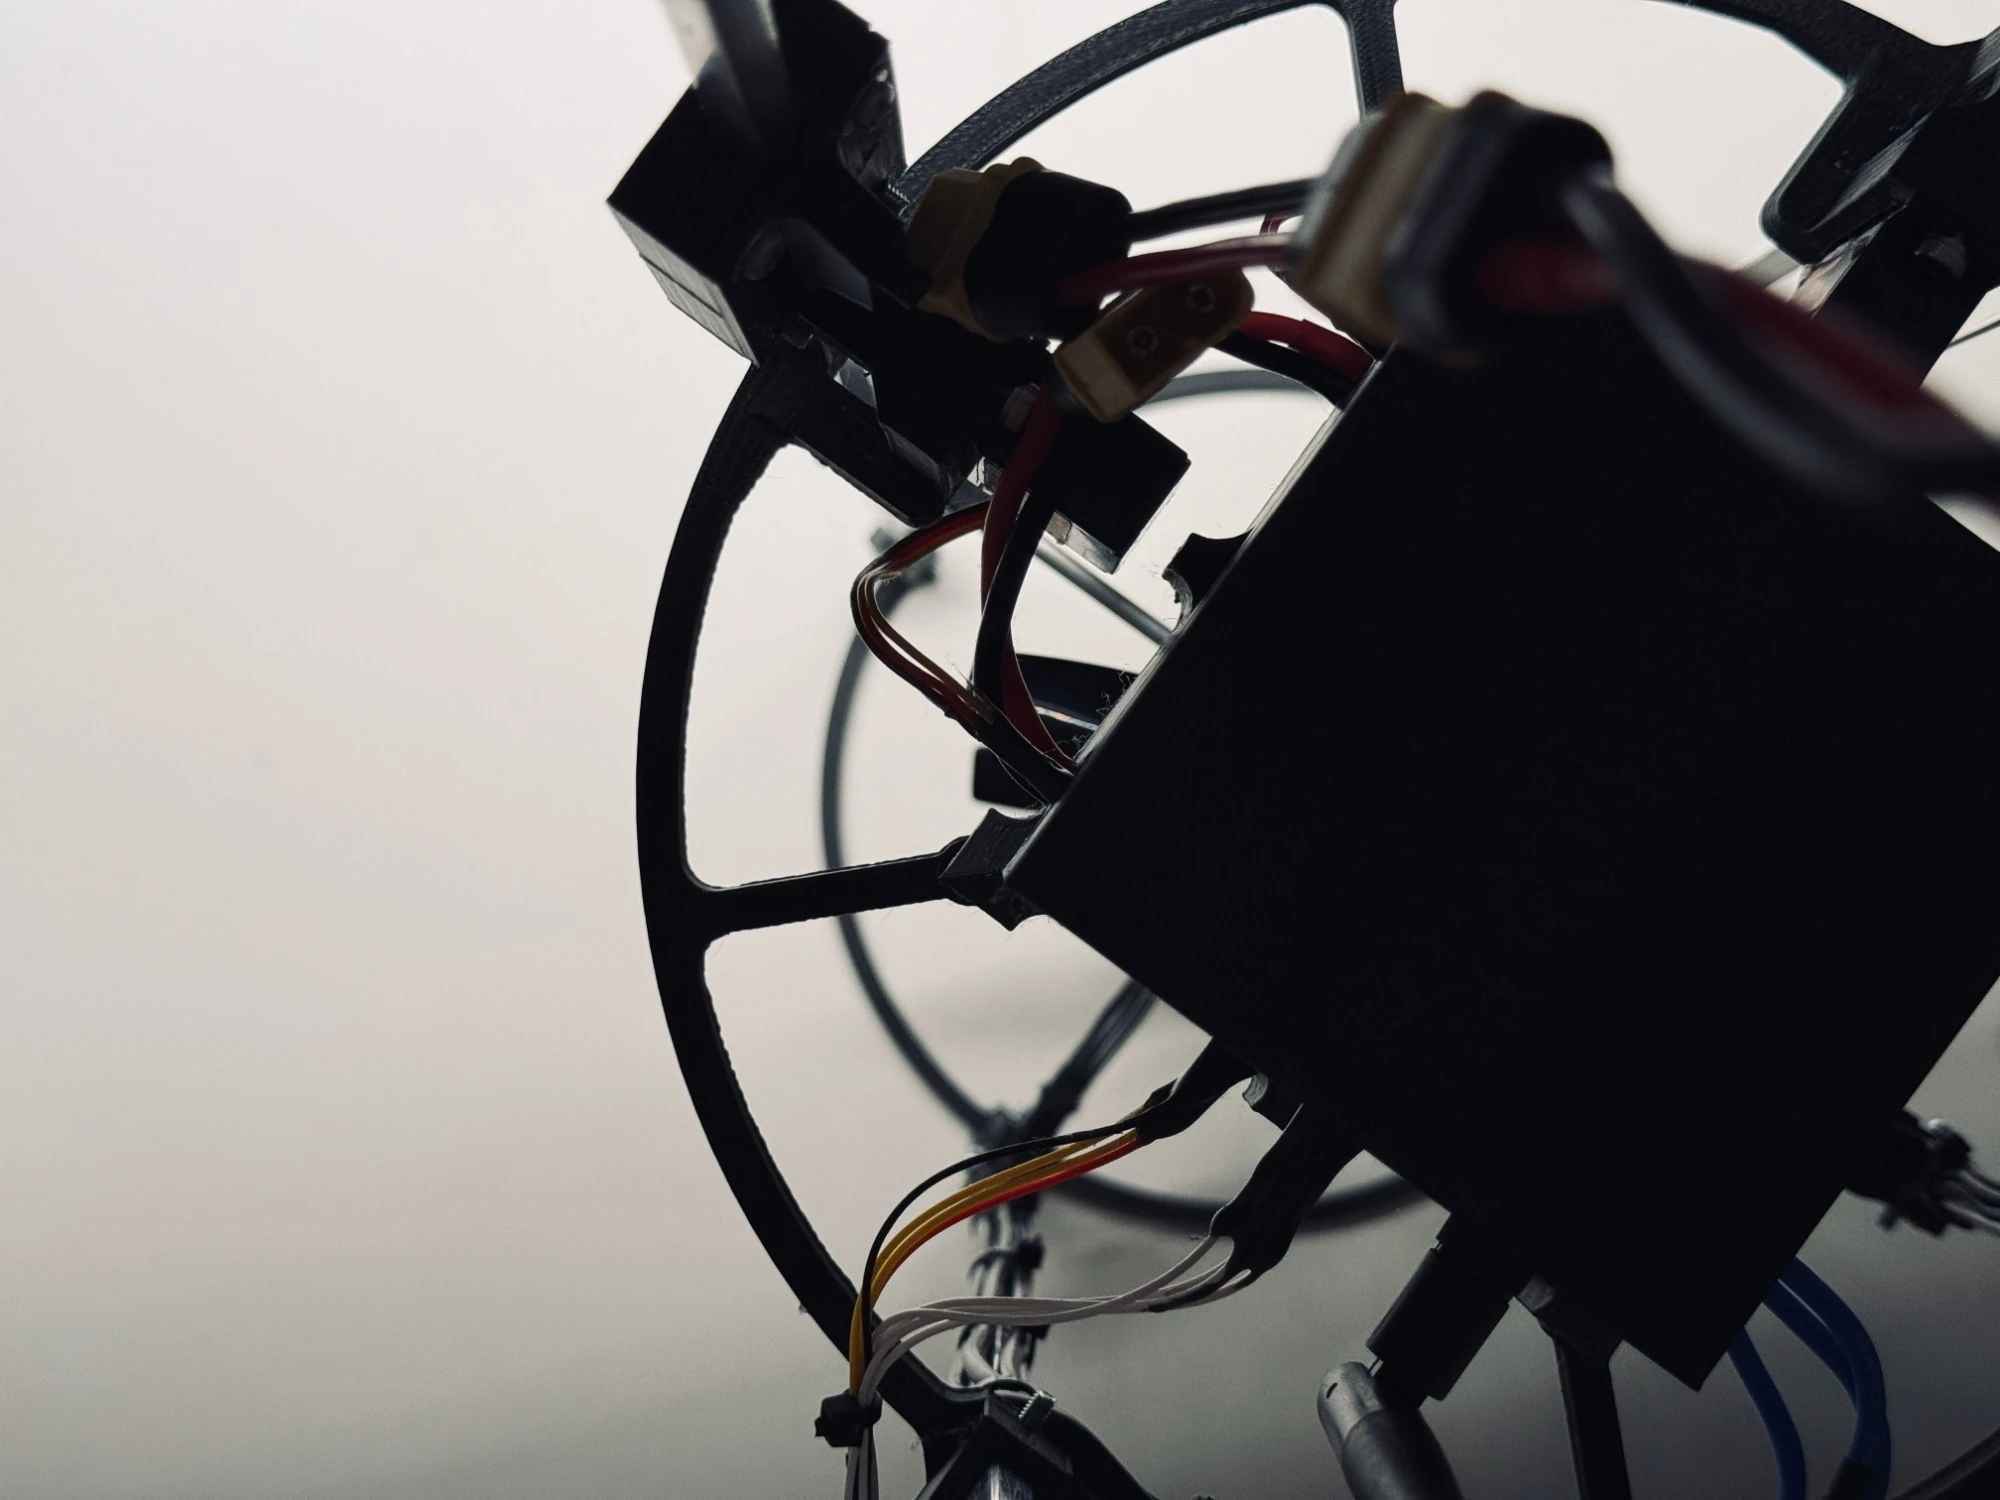
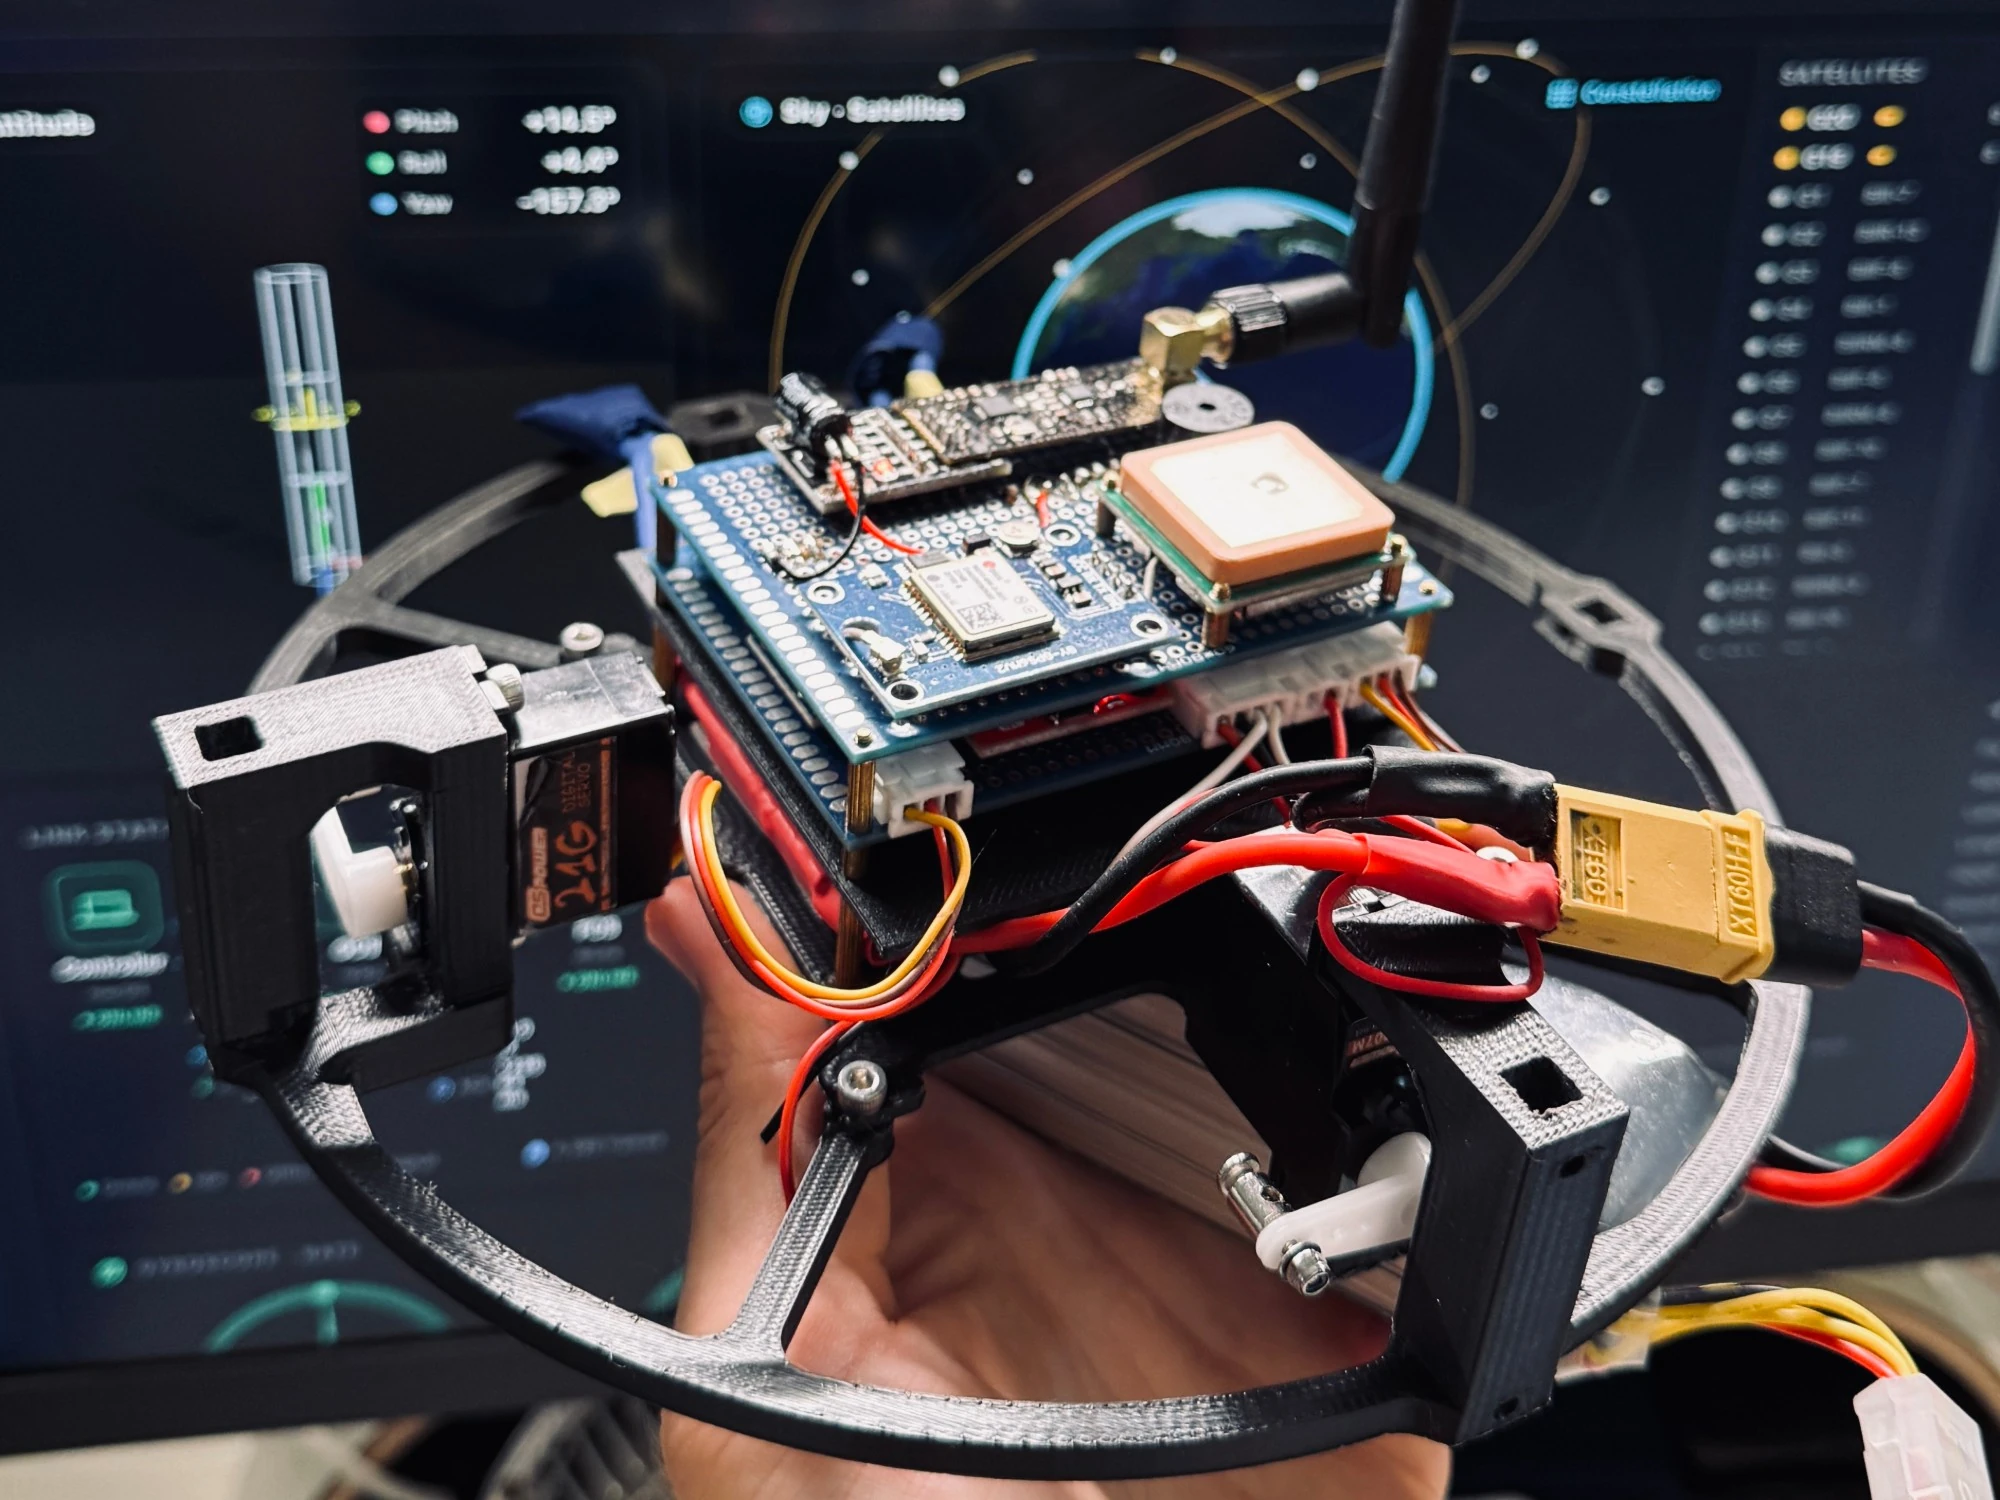
The real KAIROS on our bench: the board sealed in its printed enclosure, the harness routed along the frame ring, and every connector where the flight needs it.
Inside
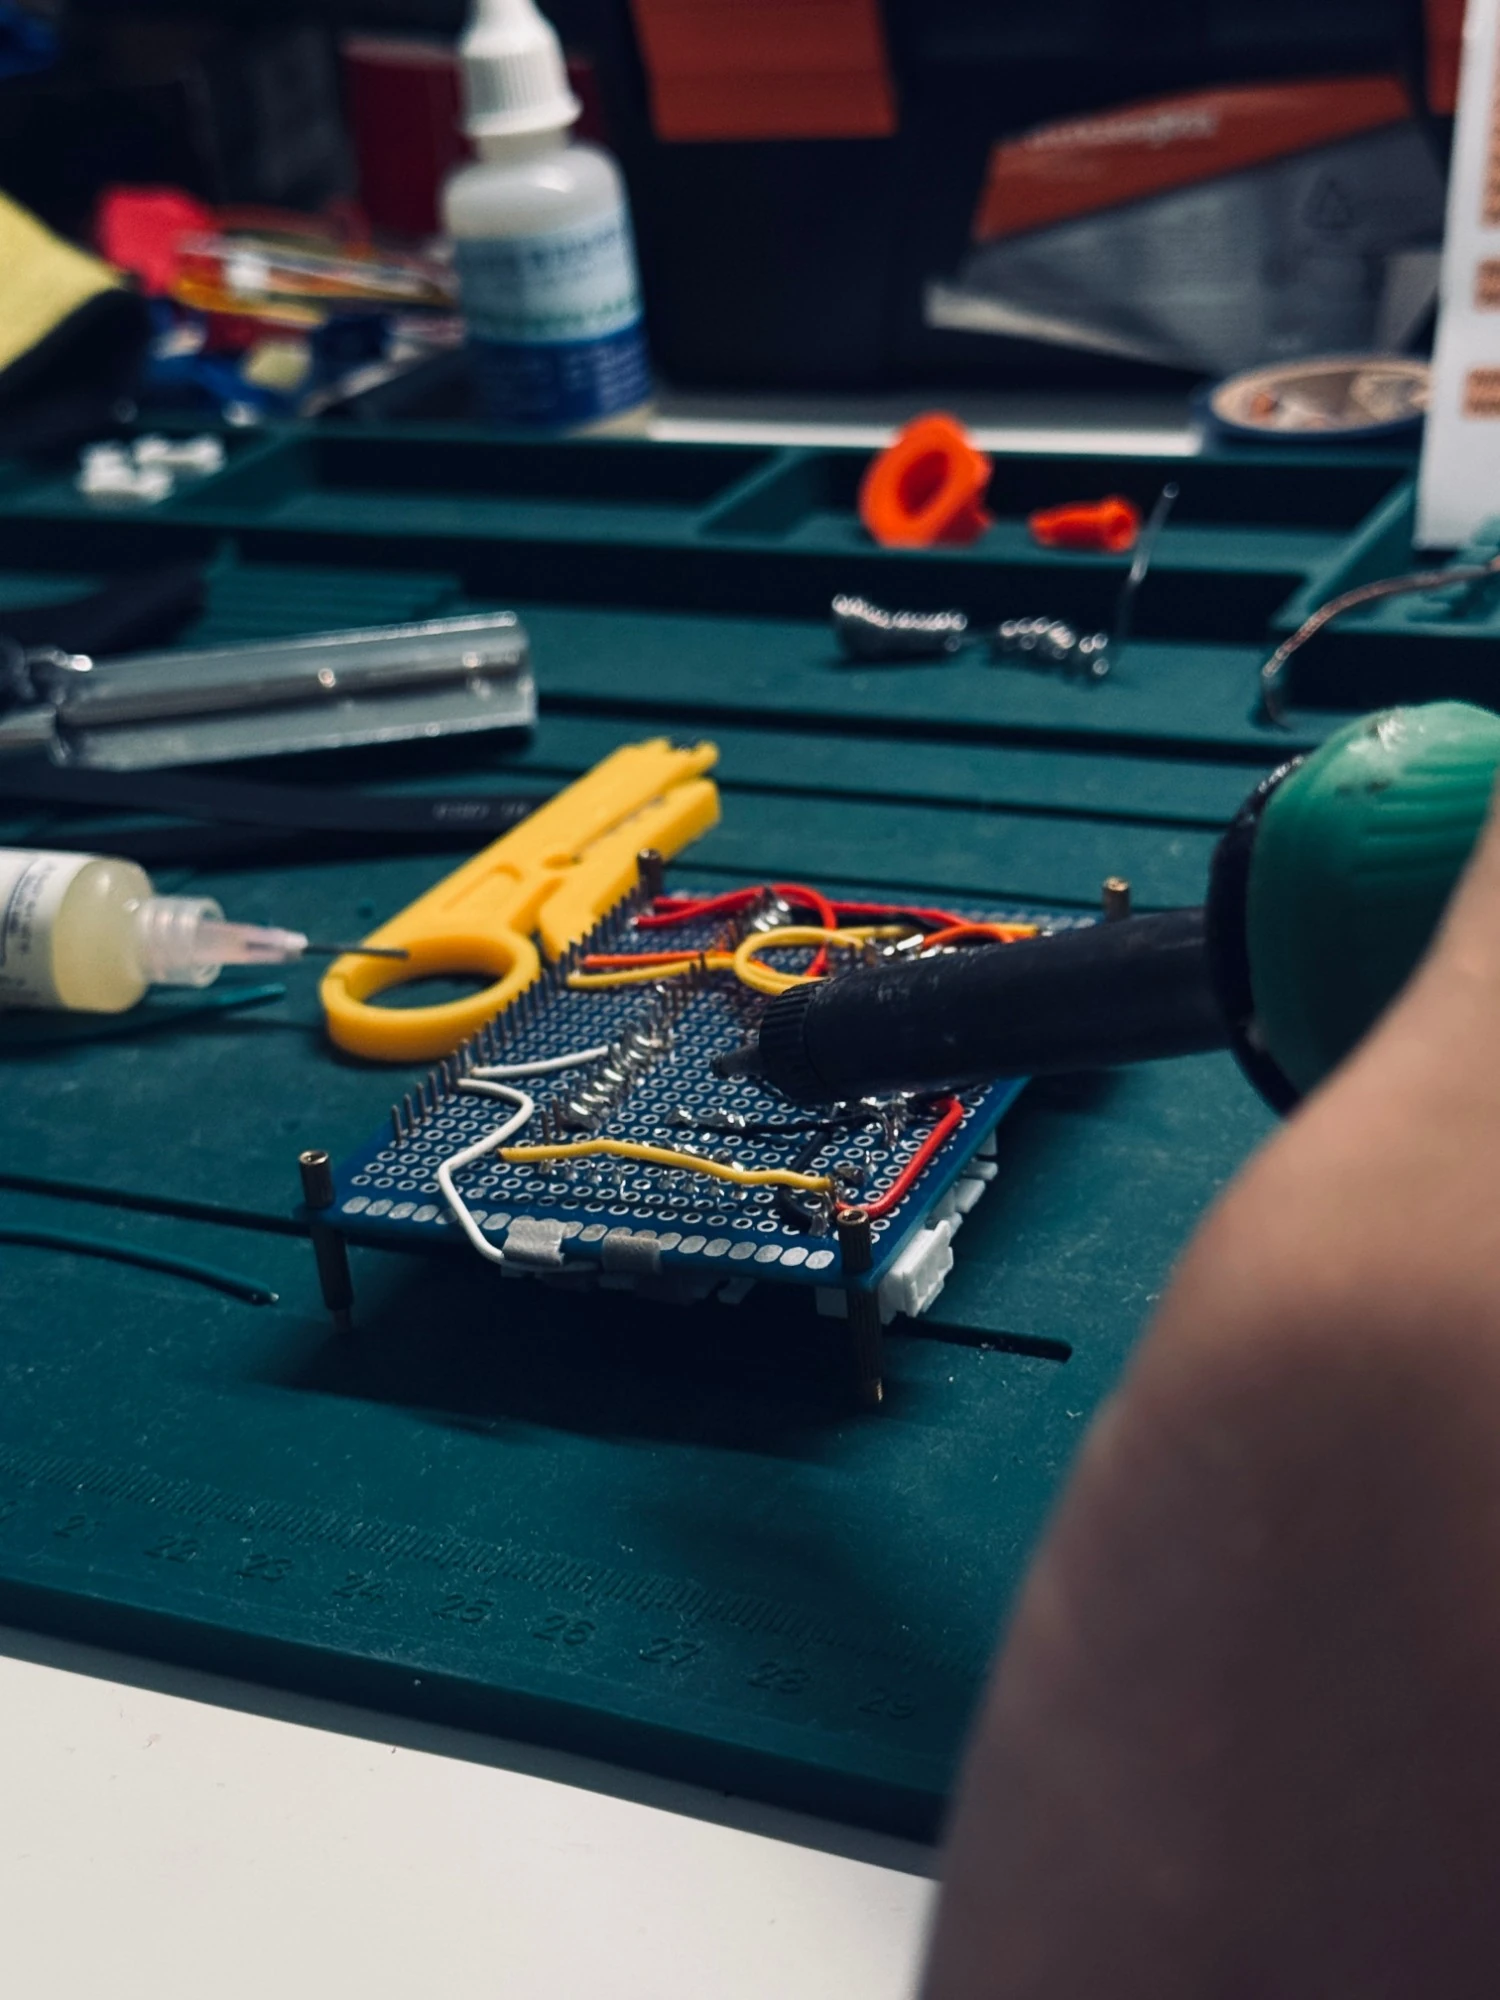
Wired by hand, layer by layer
Take the cover off and KAIROS is a stack of hand-soldered boards: the processor, the motion sensor, the GPS receiver and the long-range radio, each wired and tested on its own before it joined the stack.
Under the hood
Specifications
| Class | Custom flight computer for thrust-vectored / experimental flight |
| Processor | 32-bit ARM microcontroller with a custom sensor and module stack |
| Control rate | ~1 kHz control loop; attitude corrected about 100 times a second |
| Orientation | 9-axis motion sensor with on-chip fusion |
| Altitude | Barometric pressure sensor |
| Position | Satellite navigation (GNSS) |
| Connectivity | Wireless telemetry link |
| Software | Native desktop companion app |
| Design | Built in-house by CurrentSky |
Why we built it
A different problem
Off-the-shelf controllers are built for multirotors — inherently stable, well-served by existing firmware. Thrust-vectored flight is different: fewer motors, an unstable balance point, control through steering thrust rather than differencing it. It demands a controller tuned end to end. KAIROS is our answer — designed from the first principle of thrust-vectored control and iterated in-house, so every layer is ours to refine.
Ecosystem
Part of a larger system
CurrentSky
The independent project behind it.
AISHIP
The thrust-vectored drone KAIROS is built for. See AISHIP V3 →
KAIROS
The flight computer at its core.
Companion app
Desktop tuning, telemetry and bench tests.